欢迎访问 / WELCOME TO FAMILAB

Flexible Actuation,Manipulation and Interaction Lab

柔性机器人与智能交互实验室

Fudan University

实验室简介 / LABORATORY PROFILE

FamiLab investigates haptic perception and feedback, soft actuation and compliant structures, and origami robotics. Our research advances compliant robotic systems, high-performance actuators, high-fidelity haptic interaction and sustainable robotics.

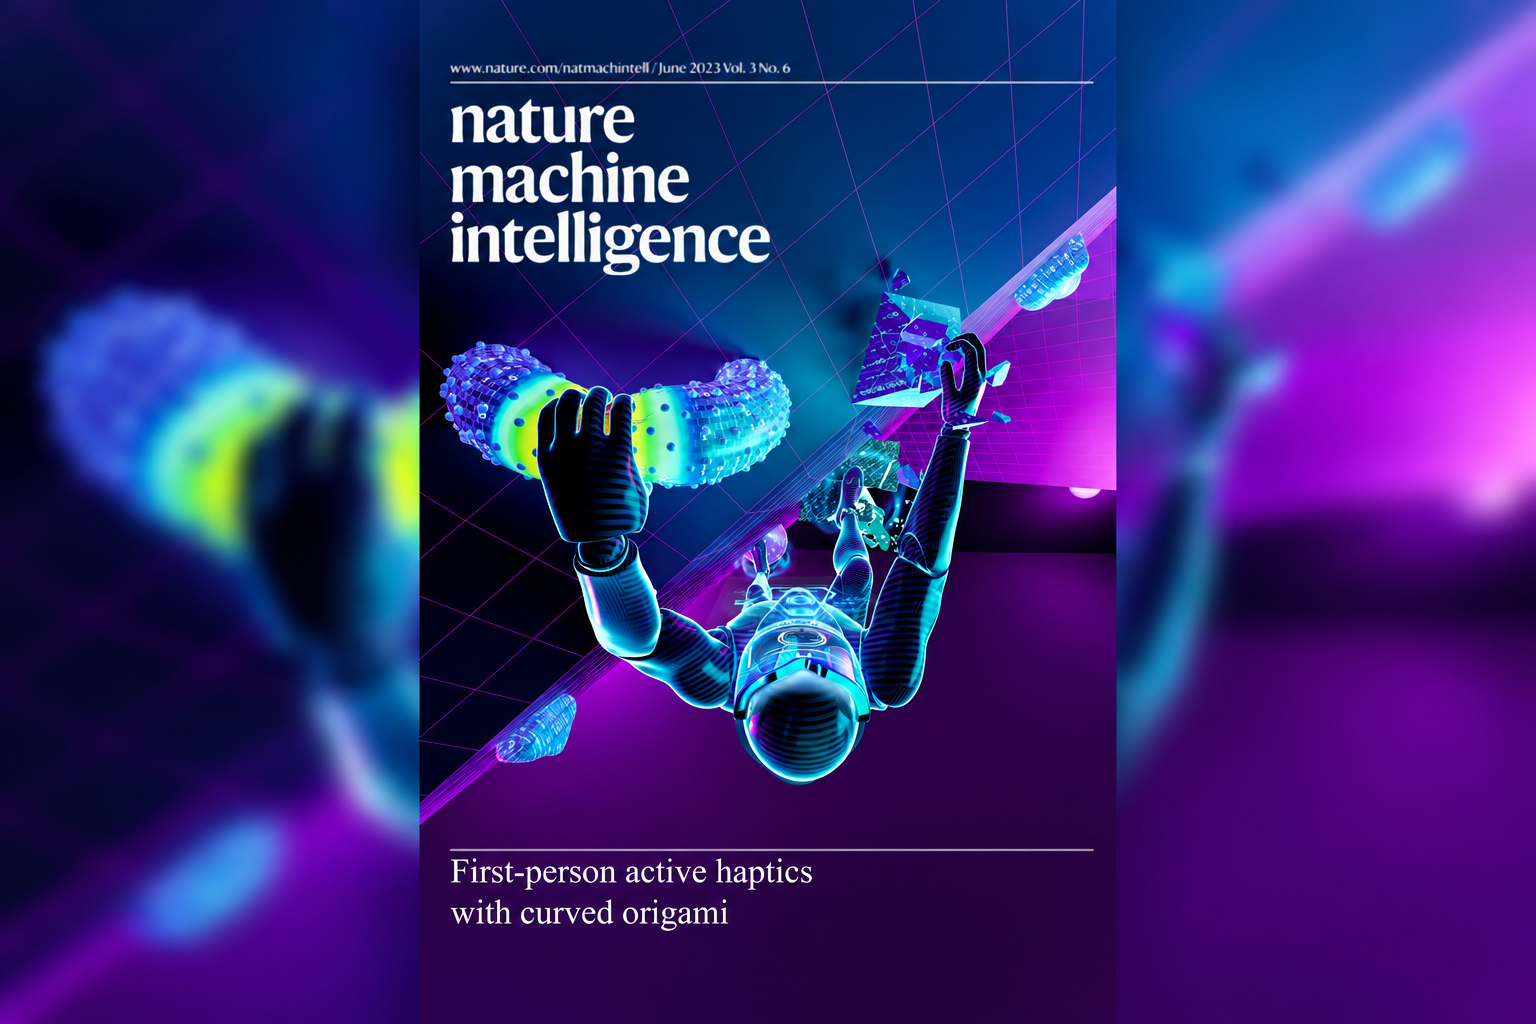
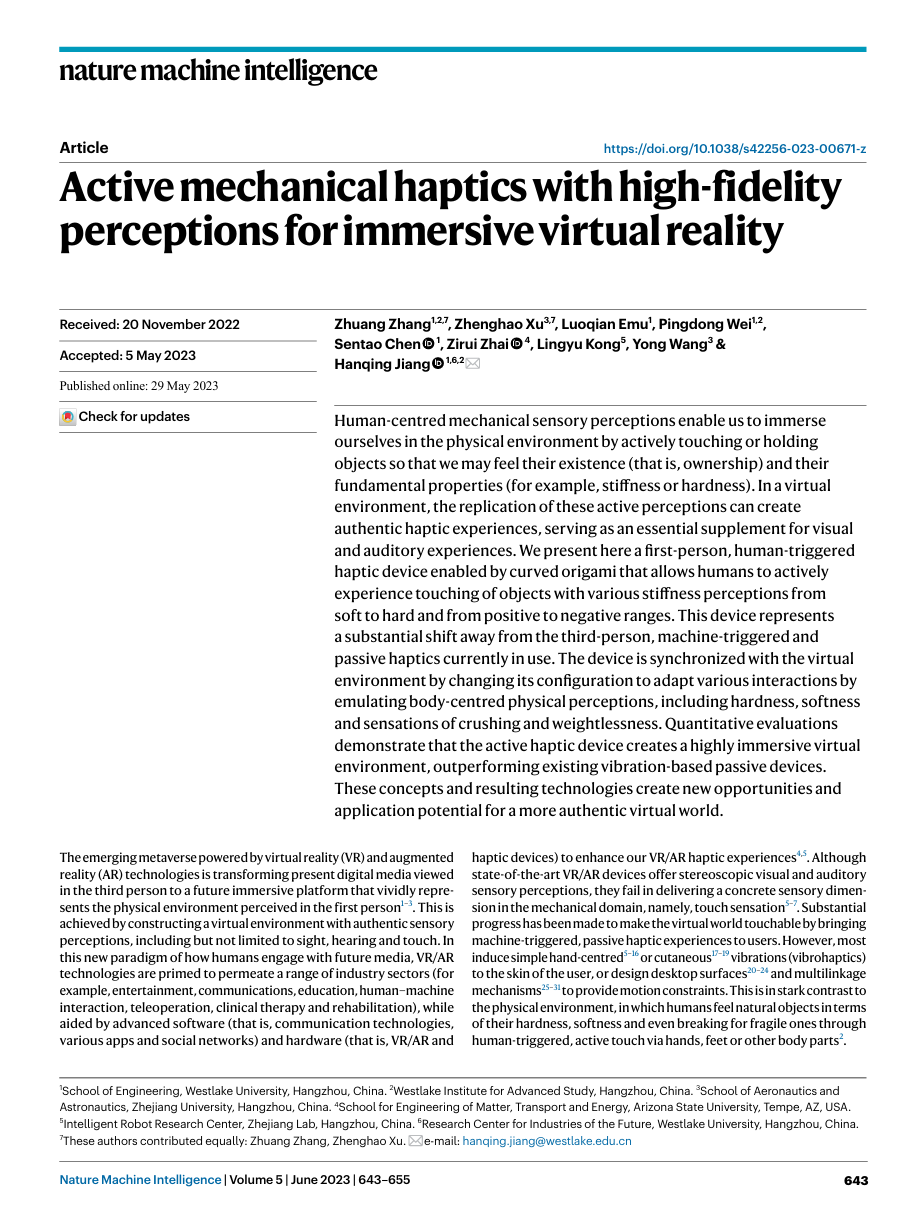
Nature Machine Intelligence cover for multimodal haptic feedback research

01Featured Research

Multimodal Haptic Perception and Feedback

Active mechanical haptics with high-fidelity perceptions for immersive virtual reality

Nature Machine Intelligence · 2023
新闻

News

More news
01Pinned
Recruitment

Join FamiLab: Postdoctoral Positions and Graduate Research Opportunities

FamiLab welcomes applications for postdoctoral positions and PhD and master's study in soft robotics, haptics and related fields.

02
Academic Exchange

Professor Zhuang Zhang Delivers an Invited Talk at the International Symposium on Flexible Electronics

The International Symposium on Flexible Electronics took place in Wuhan on October 23, 2026. Professor Zhuang Zhang delivered an invited talk.
03
Academic Exchange

Professor Zhuang Zhang Chairs the Soft Robotics Forum at the Soft Matter Mechanics Conference

The Soft Matter Mechanics Conference took place in Wuhan on October 23, 2026. Professor Zhuang Zhang attended the conference and chaired its Soft Robotics Forum.

研究方向

Research

Multimodal Haptic Perception and Feedback research image01

FamiLab / 01

Multimodal Haptic Perception and Feedback

We investigate active and passive haptic systems that deliver high-fidelity haptic sensations and full-body multimodal feedback for immersive virtual reality.

  • Active mechanical haptics
  • Bistable haptic textiles
Rigid–Soft Hybrid Metamaterials, Actuators and Sensors research image02

FamiLab / 02

Rigid–Soft Hybrid Metamaterials, Actuators and Sensors

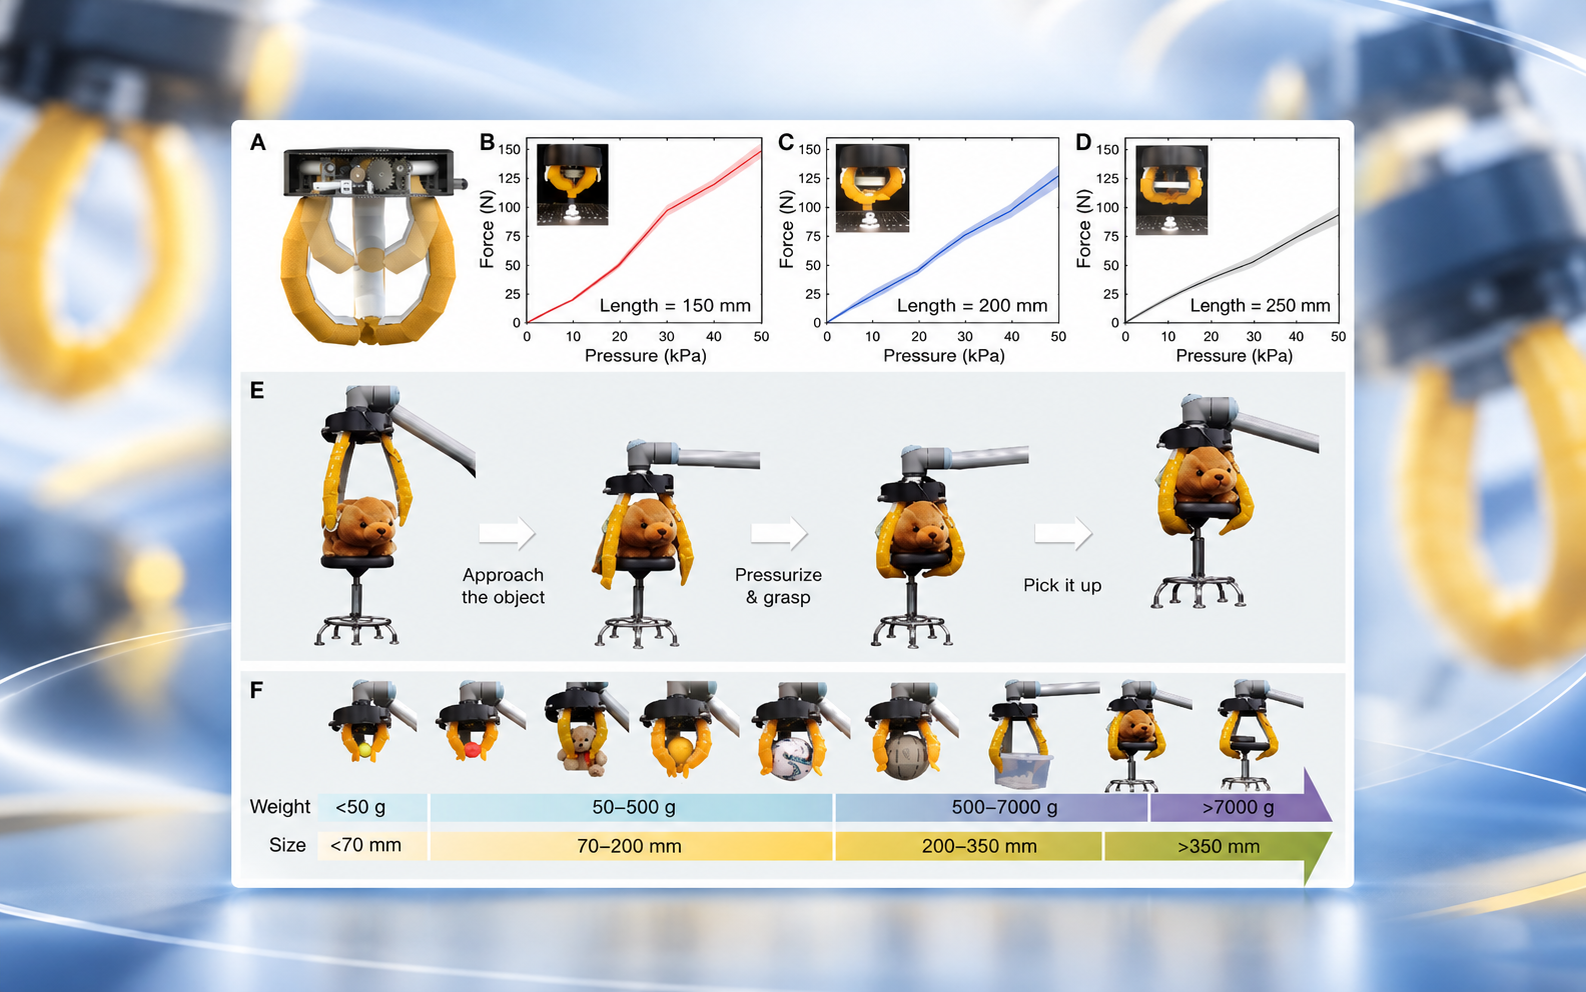
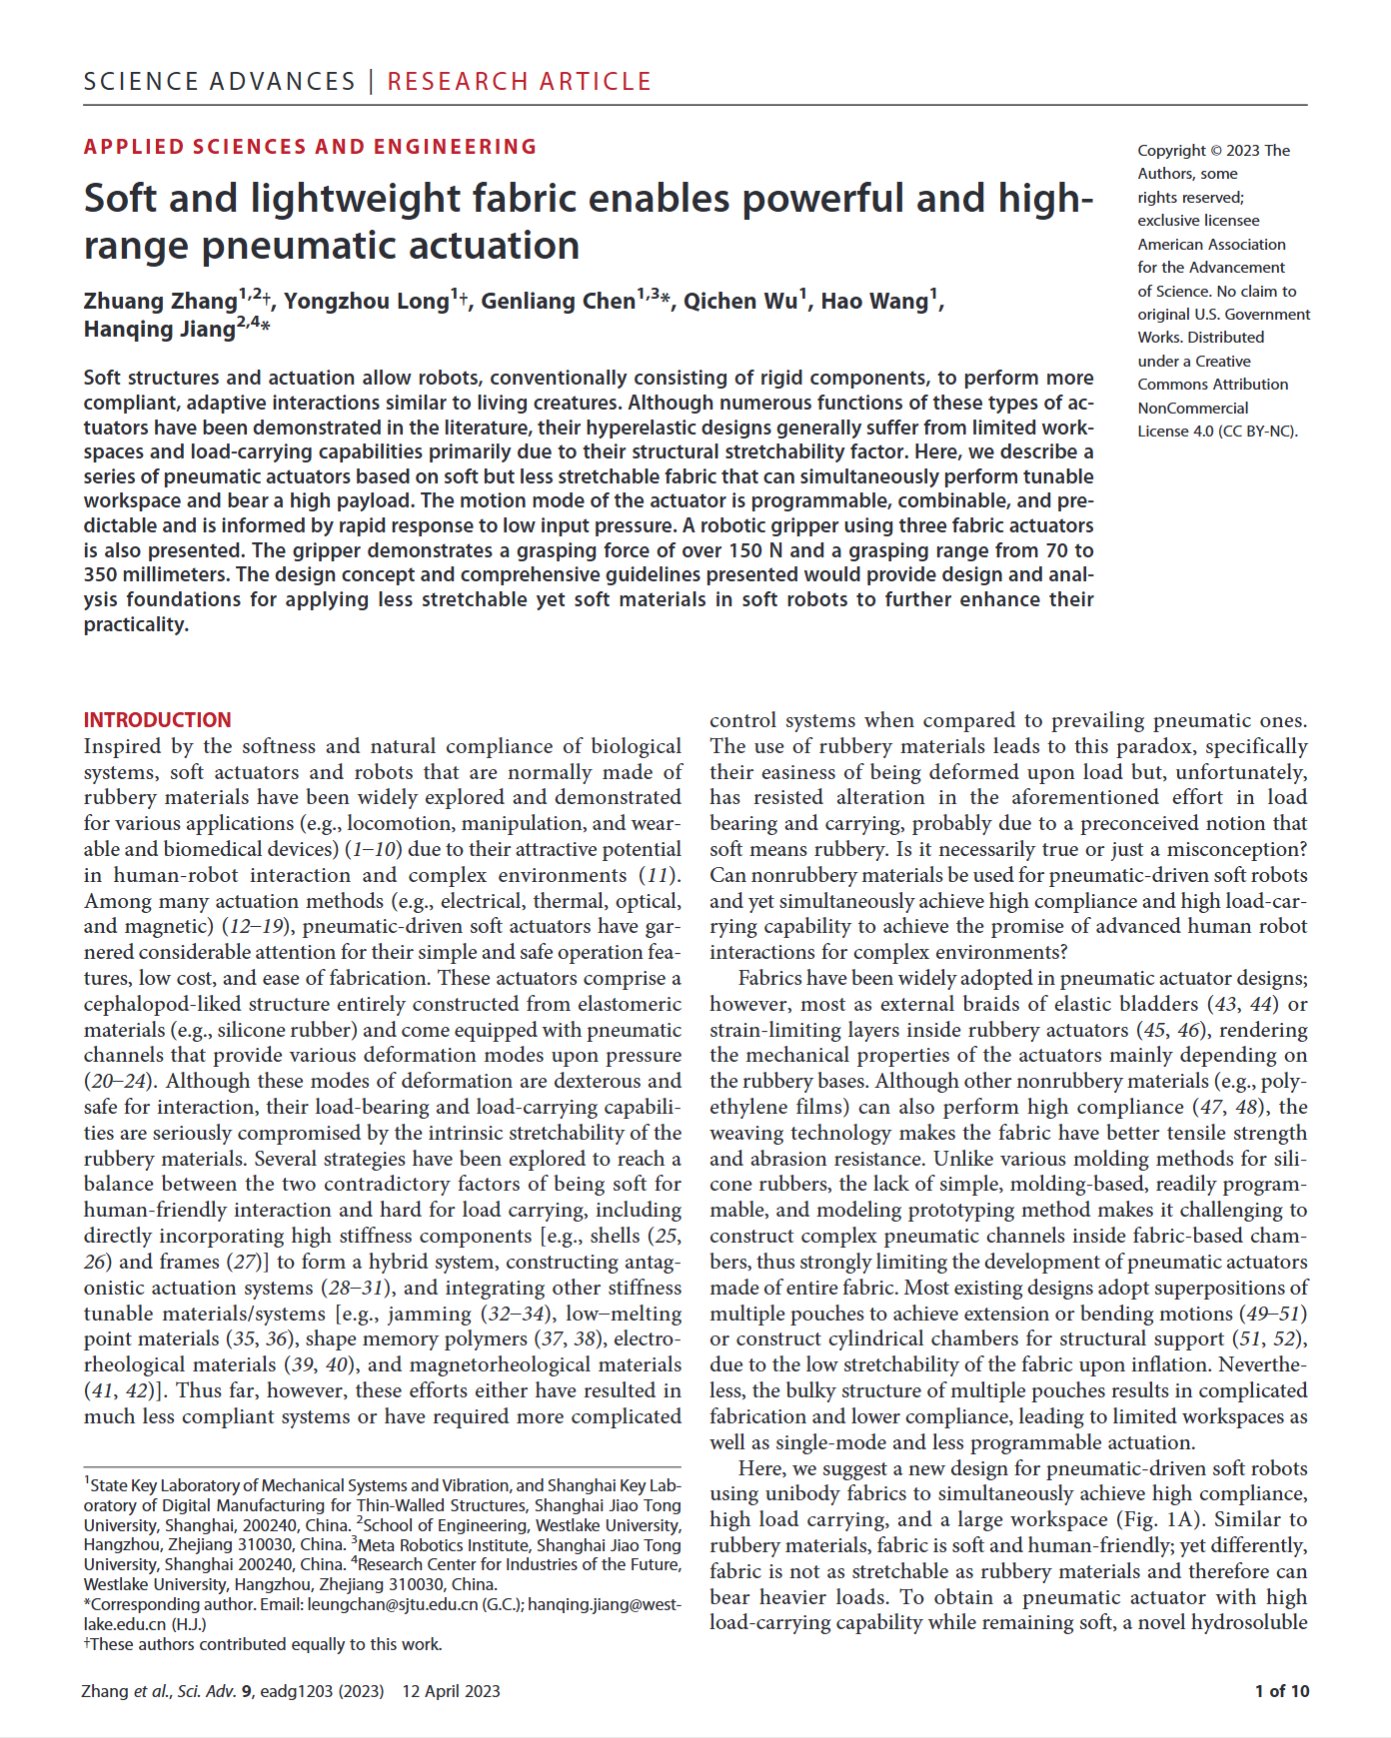
We investigate soft actuators and sensors with high load capacity, high precision and multimodal functionality, alongside rigid–soft hybrid robotic systems and mechanical metamaterials.

  • Fabric-based pneumatic actuators
  • Electronics-free pneumatic oscillators
Origami, Soft and Continuum Robots research image03

FamiLab / 03

Origami, Soft and Continuum Robots

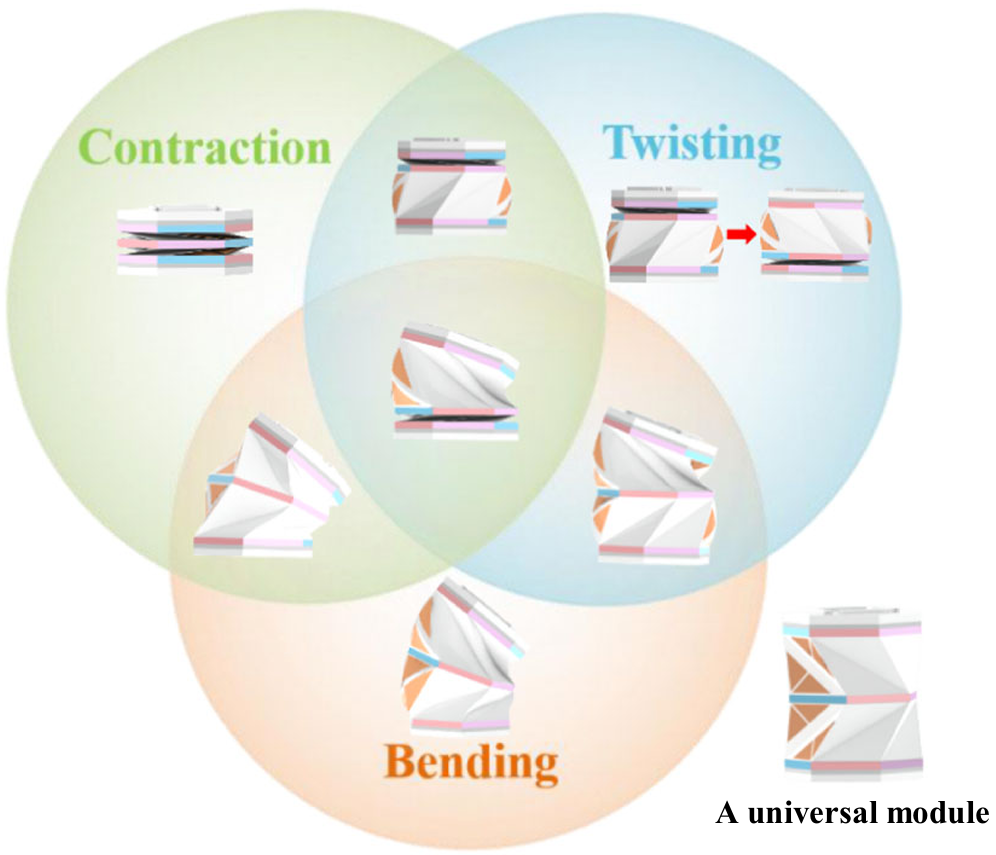
We explore origami structures and mechanical metamaterials for high-performance reconfigurable robots and sustainable robotic systems.

  • Origami modules with versatile deformation modes
  • Biodegradable robots for closed-loop sustainability